Juice Flow Anomaly Detection: Food-Safety Edge Segmentation
U-Net segmentation R&D for inspecting juice-flow imagery, with temporal confirmation and a planned Jetson Orin Nano deployment path.
Internal R&D / Personal Engineering Project at Bondstein Technologies Ltd.
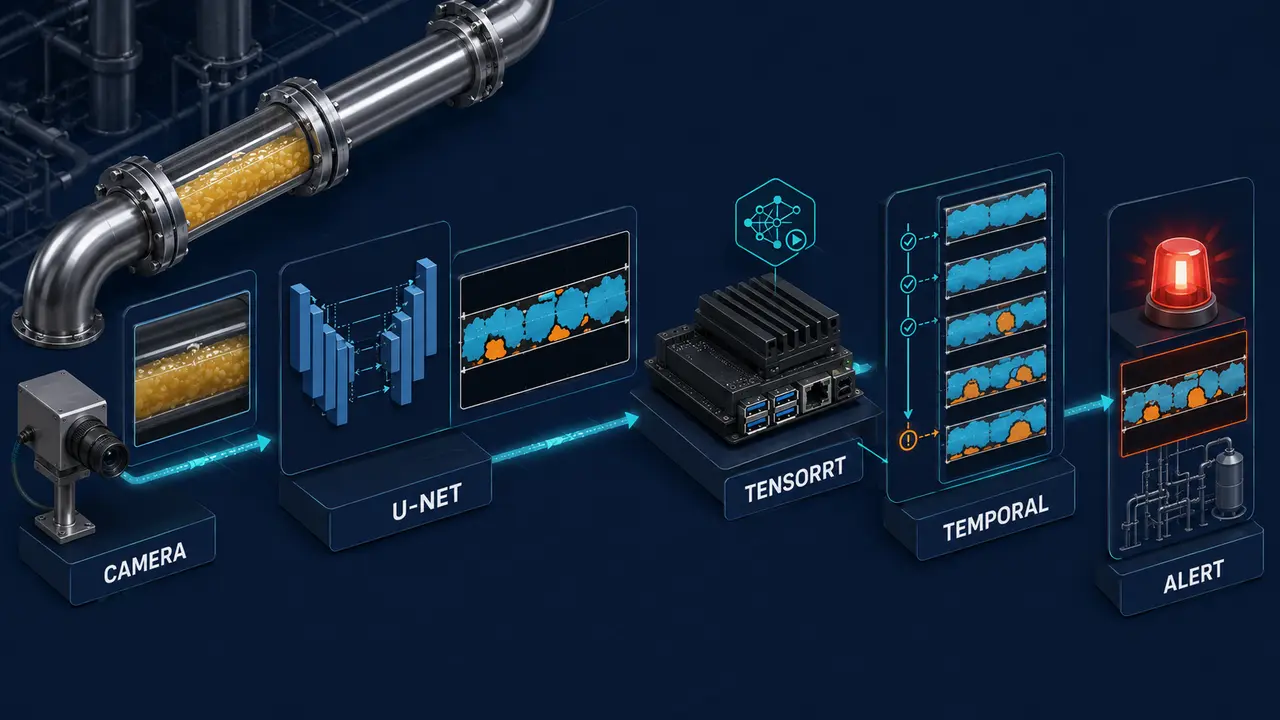
Workflow at a glance
Acquire pipe imagery
Prepare inspection frames.
Segment candidate regions
Estimate anomaly regions using U-Net.
Confirm over time
Consolidate signals and inspect evidence.
Planned edge validation
Evaluate Jetson and TensorRT deployment.
Project facts & reported results
Implementation fact
Implementation fact
Project Overview
Problem Statement
Food-safety inspection of juice-flow pipes required continuous, real-time monitoring for anomalies (contamination, discoloration, blockage). Manual inspection was inconsistent and couldn't cover all production lines simultaneously.
Approach & Methodology
Developed U-Net segmentation model for pixel-level anomaly detection in juice-flow pipe imagery. Planned deployment on Jetson Orin Nano with TensorRT FP16/INT8 optimization for real-time edge inference. Evaluation emphasis on IoU, precision, recall, false alarm rate, and temporal confirmation to reduce false positives.
Outcome & Scope
Developed a segmentation approach and temporal confirmation workflow for pipe-image inspection. Jetson deployment and TensorRT optimization remain development targets.
System Architecture
Segmentation and event review, with edge optimization kept separate as planned work.
Key Components:
Acquire frames showing the inspection region.
Estimate candidate anomaly regions with U-Net.
Consolidate observations across frames.
Inspect evidence; validate Jetson and TensorRT deployment separately.
Key Features & Capabilities
U-Net segmentation of pipe imagery
Temporal confirmation of candidate anomalies
Image evidence for inspection review
Planned target-hardware evaluation on Jetson Orin Nano
Current Scope & Limitations
Target-hardware speed, segmentation quality, and false-alert rates are not independently benchmarked here.
TensorRT precision conversion and Jetson deployment are planned, not completed results.
Technologies & Tools
Planned technologies
- NVIDIA Jetson Orin Nano
- TensorRT FP16 / INT8